Paper | Project Page | Citation | License
Status: Under review. The source code and installation instructions will be released after the review process.
Authors: Yuhao Cao, Xiao Liu, Yang Xie, Lu Liu, Haoyao Chen
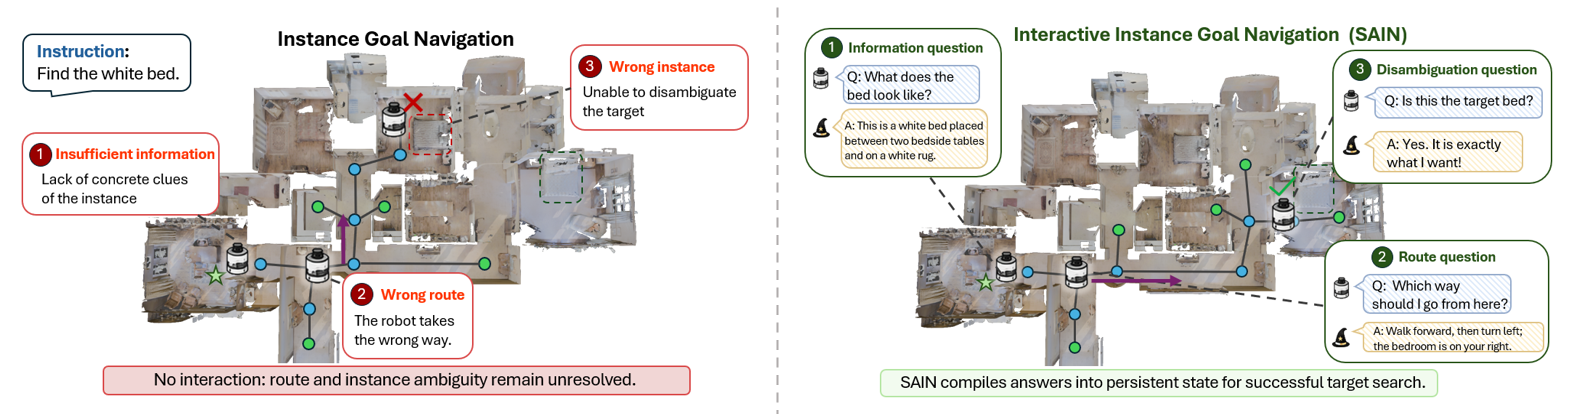
SAIN is a zero-shot framework for Interactive Instance Goal Navigation (IIGN). It enables an embodied agent to resolve ambiguous category-level instructions through active dialogue and locate the user-intended object instance without task-specific policy training.
The core idea is dialogue-to-state conversion. Instead of treating oracle answers as transient textual hints, SAIN compiles them into persistent target evidence, route-level corridor memory, and object-candidate labels. These states are maintained in structured value, room, graph, and object memories and consumed by a unified policy for frontier ranking and final target approach.
On the VL-LN IIGN benchmark, SAIN improves success rate from 20.2 to 25.4 and SPL from 13.07 to 14.17 over the strongest reported dialogue-enabled baseline.
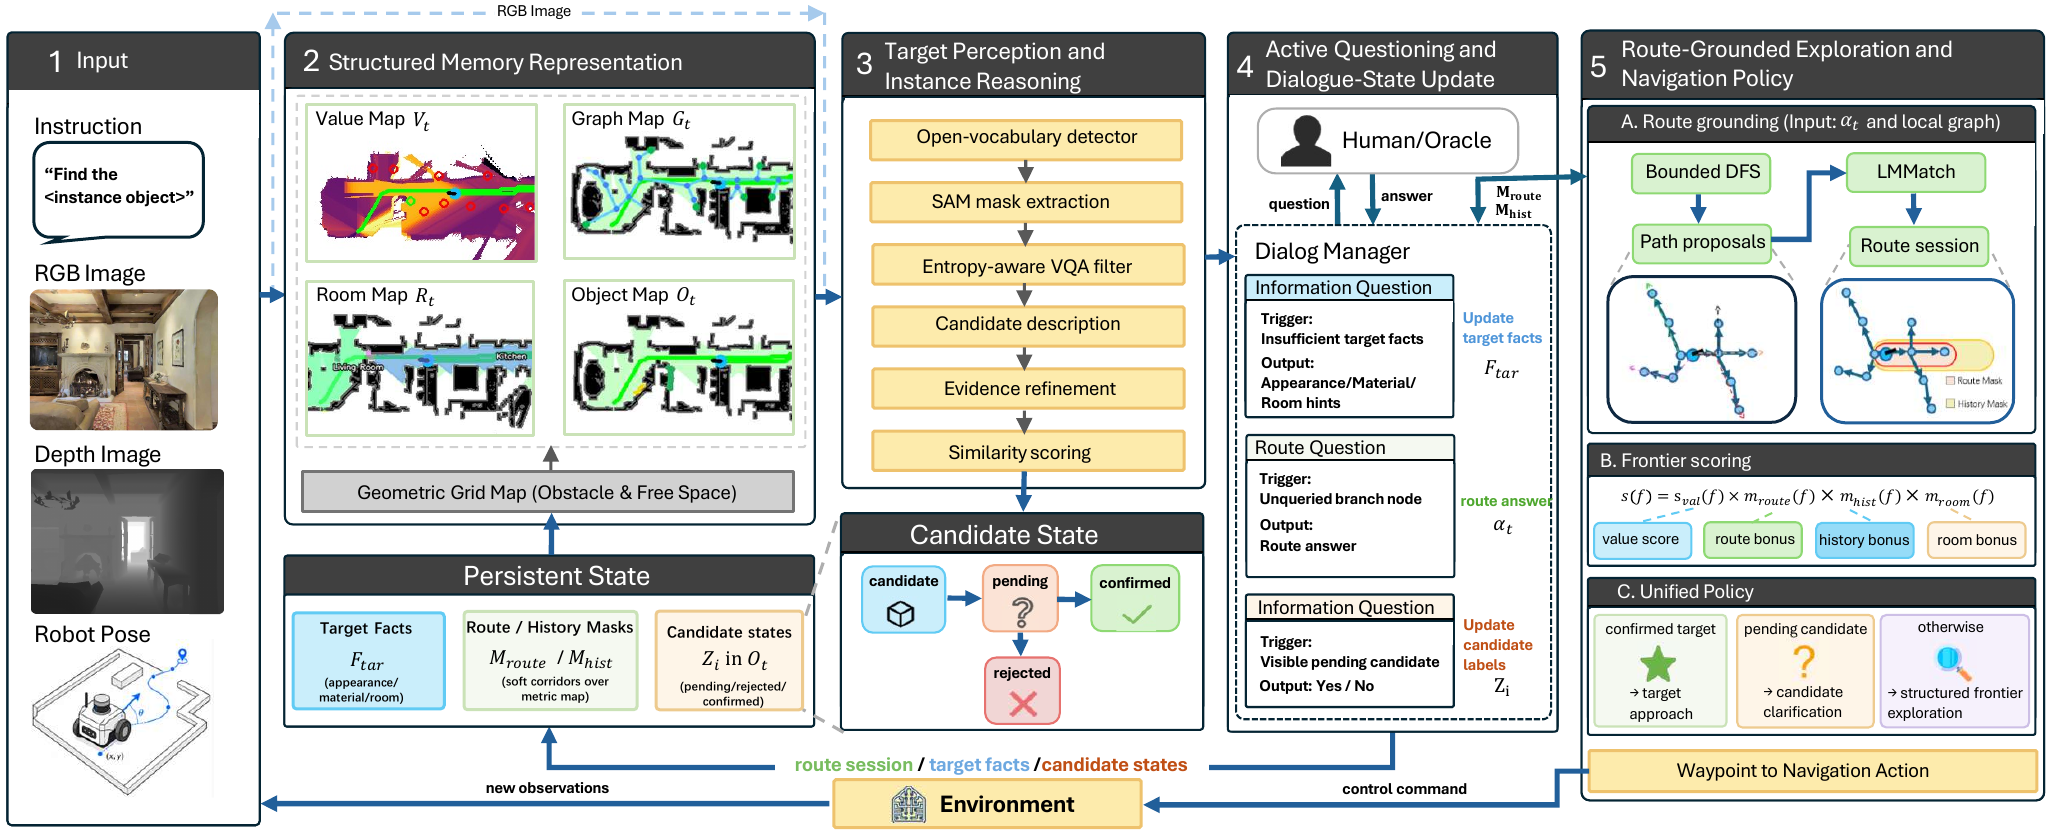
SAIN is currently under review. The source code, environment specification, pretrained model requirements, and reproducible installation instructions will be released in this repository after the review process.
If you find SAIN useful for your research, please cite our paper:
@article{cao2026sain,
  title={SAIN: Structure-Aware Interactive Navigation with Active Dialogue Grounding for Mobile Robot},
  author={Cao, Yuhao and Liu, Xiao and Xie, Yang and Liu, Lu and Chen, Haoyao},
  journal={arXiv preprint arXiv:2608.09196},
  year={2026}
}
License information will be provided when the source code is released. Third-party datasets, models, and software remain subject to their respective licenses and terms of use.